Automation engineering for machine builders, system integrators and manufacturers
Robot programming
Motion programs and cell integration for robots doing real production work — welding, bonding, screwdriving, handling and machine tending.
Robot platforms
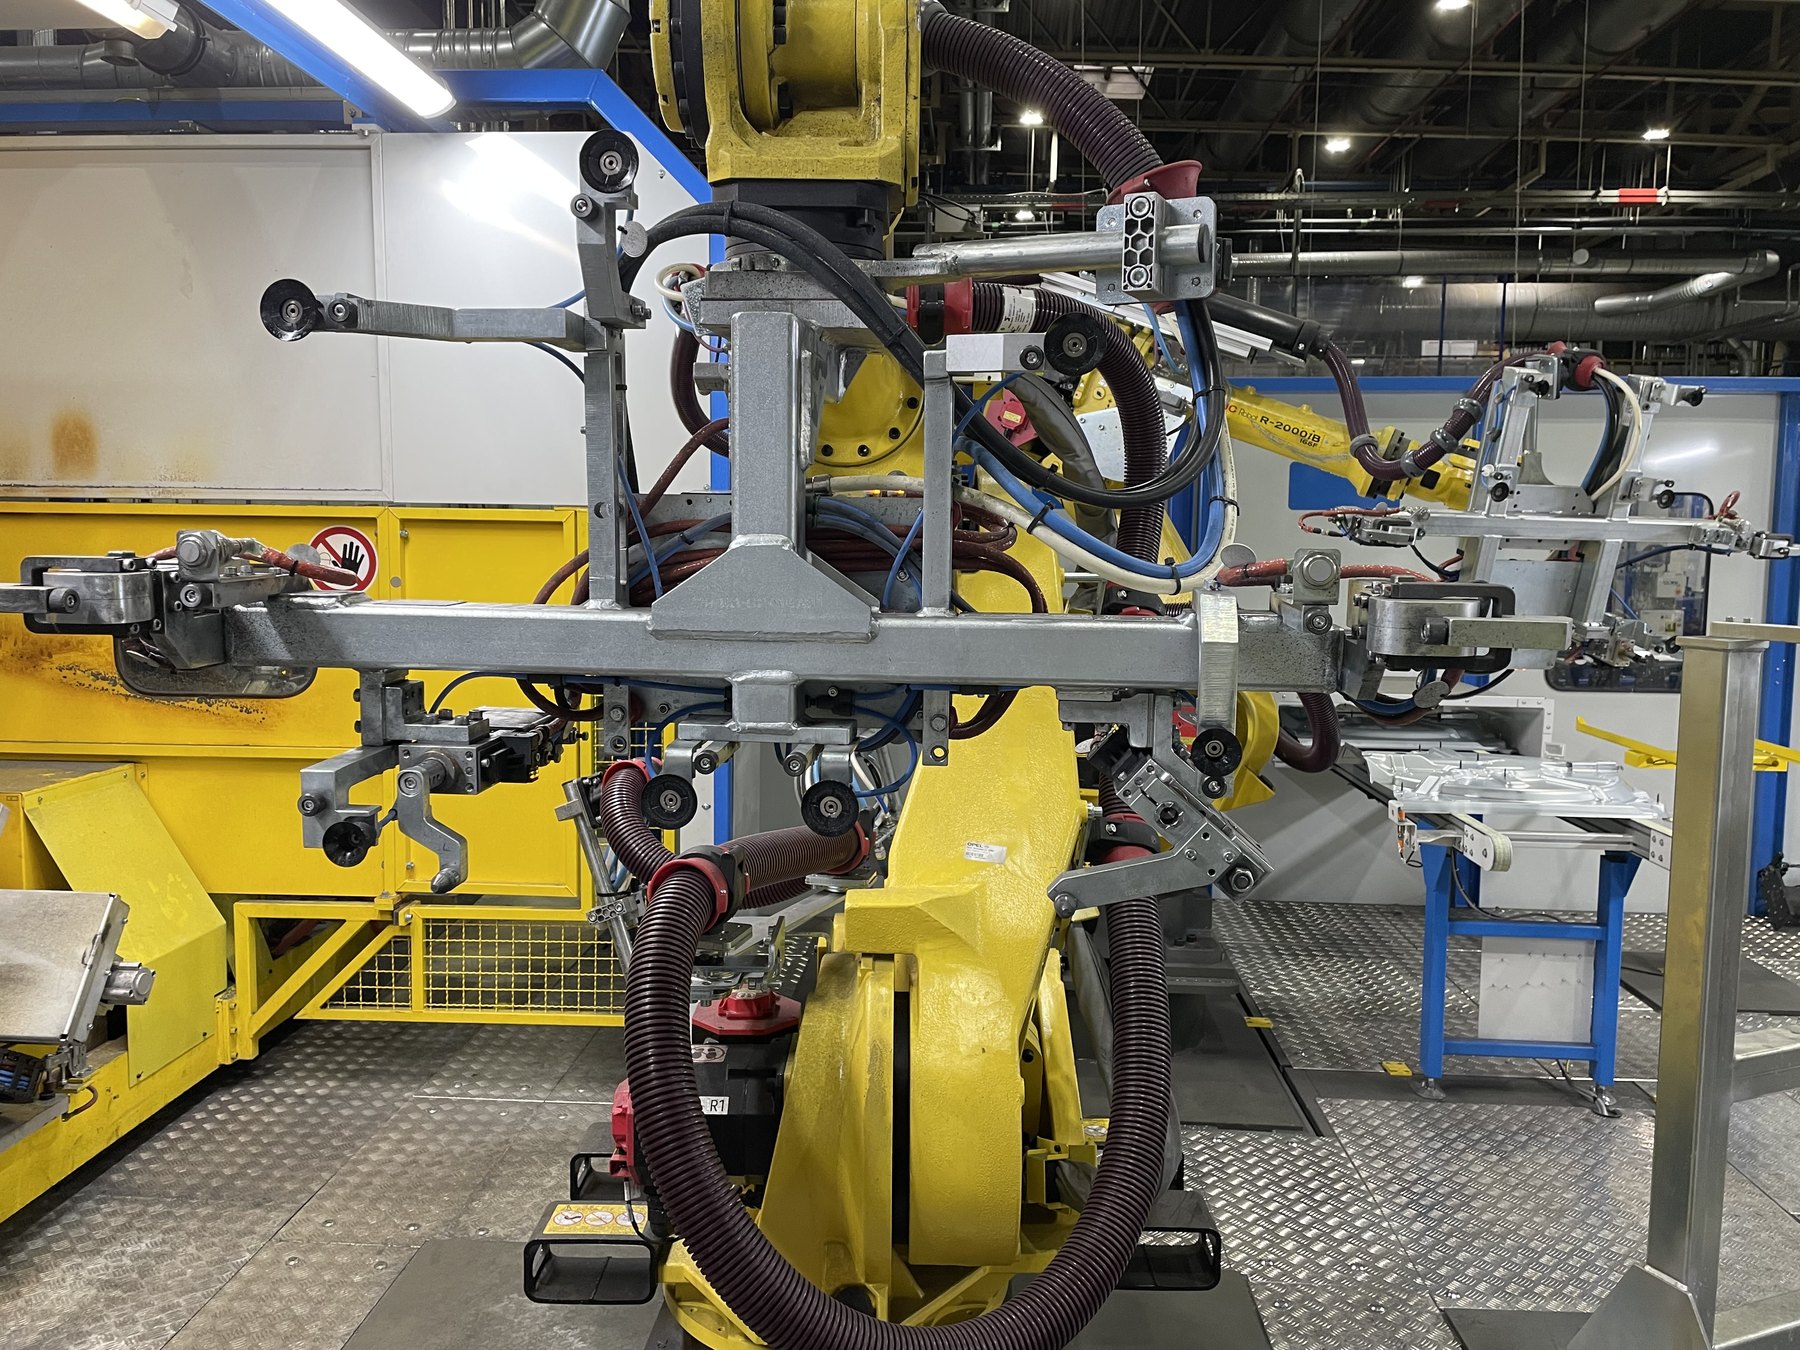
| FANUC | M-900iA, R-2000iB, R-2000iC, LR Mate 200iD and comparable — handling, spot welding, projection welding, adhesive application. |
|---|---|
| KUKA | KRC4 and KRC5 controllers. KR 10, KR 120, KR 150, KR 210 and larger; KUKA SCARA. |
| ABB | IRB 6650S and comparable six-axis handling robots. |
| Yaskawa and Kawasaki | Six-axis handling and welding robots, on lines built around them. |
| Collaborative | KUKA LBR iiwa, Universal Robots UR10, and the EVA robot for label application, where the application calls for a collaborative machine. |
| Another brand | A robot brand we have not worked with is a different pendant and a different syntax; the cell logic, the PLC interface and the safety concept are the same work. |
| Vision | Cognex, Keyence, SICK and IFM — part presence, position correction and quality inspection. |
| Process tooling | FerRobotics force-controlled tooling, adhesive and priming systems, flame treatment, welding guns, screwdriving units. |
What the work involves
- Motion programs with trajectories optimised for cycle time and for the mechanical life of the robot
- Tool and base calibration, frame definition, and the documentation to reproduce them after a crash
- Safe, explicit PLC interfaces — a signal list both sides agree on before anything is written
- Vision integration: position correction and inspection results handled as part of the cell sequence rather than bolted on
- Multi-robot cells where several arms share space and have to be sequenced without collisions
- Collaborative applications, with the force and speed limits set by the risk assessment
Applications delivered
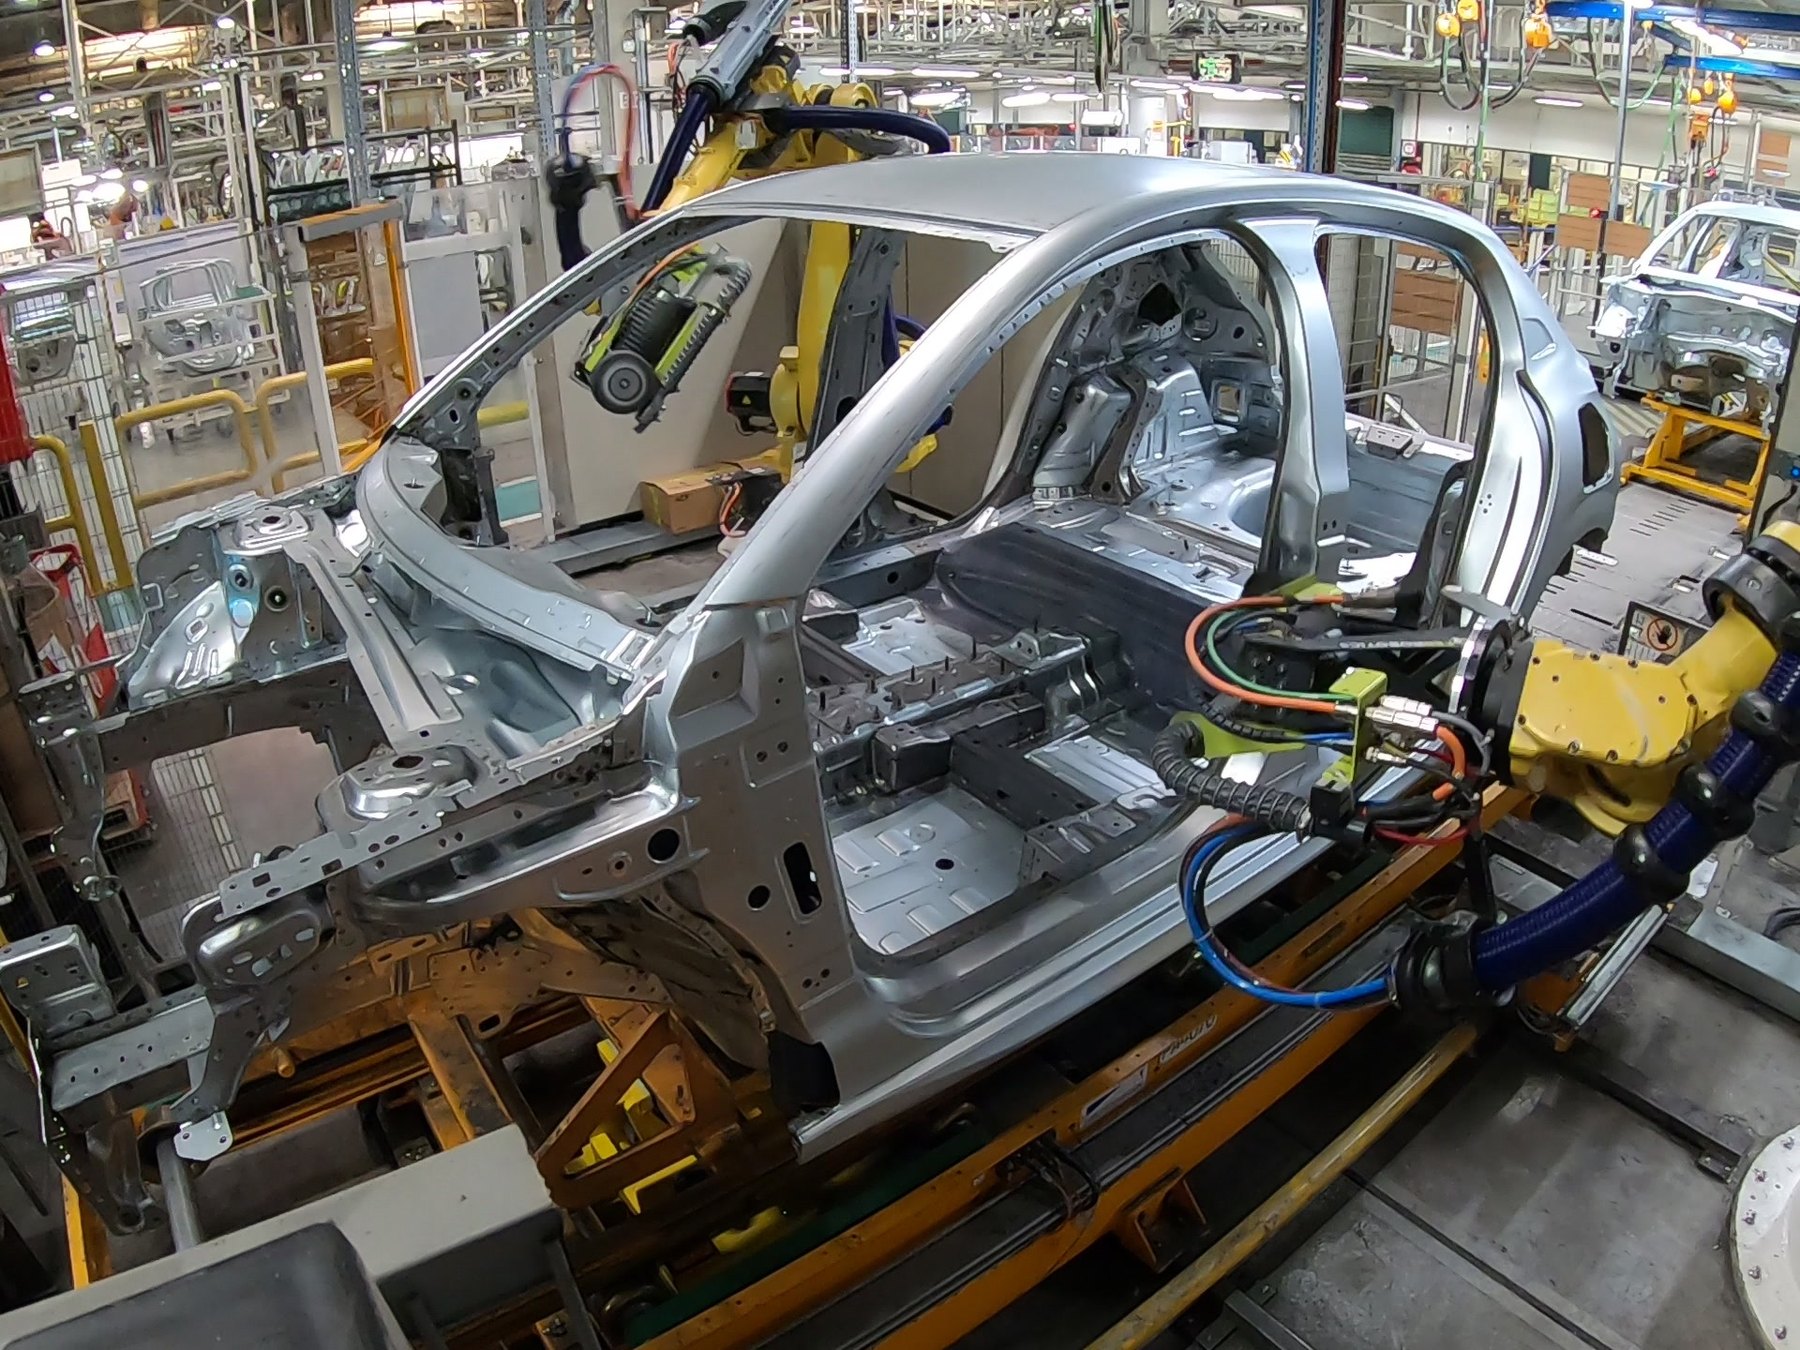
- Spot welding and projection welding cells for body-in-white and structural parts
- Adhesive bonding, priming and flame treatment for plastic body panels
- Screwdriving and fastening, including collaborative cells working next to operators
- Part removal and insert feeding on injection-moulding machines
- Assembly and positioning of large body components with sensor-based position correction
- Surface finishing with force-controlled tooling
- Labelling, marking and traceability applications